Note
Type 0, 1, 2, 3 Systems
Topics: Feedback Control Systems
The type of the system refers to the number of poles at the origin in the system, also known as free integrators.
Type 0:
Type 1:
Type 2:
Type 3:
The system type relates to the steady-state error of the system given certain types of inputs:
For zero steady-state error to a waveform with a Laplace transform , the forward transfer function must have at least free integrators.
In other words,
- to have for a step input (constant position), the system must be at least Type 1
- to have for a ramp input (constant velocity), the system must be at least Type 2
- to have for a step parabolic input (constant acceleration), the system must be at least Type 3
The table below summarizes the steady-state error conditions
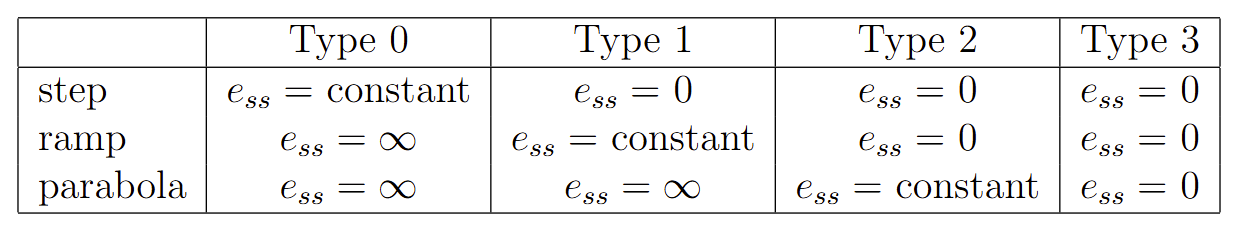
References
Backlinks
Notes that reference this page.
Connections
Direct relationships to this note.