Note
Policy
Topics: Reinforcement Learning
Action Space
The action space is the set of all the valid actions that can be taken. We differentiate between:
- discrete action space: finite set of actions
- continuous action space: infinite set of actions
Policy
The policy is the rule that is used by the agent to decide what action to take. We distinguish between:
- deterministic policy:
- stochastic policy:
In deep RL, we deal with parametrized policies, which are functions that depend on a set of parameters, most commonly a neural network.
1. Deterministic Policy
The goal of the agent is to learn one deterministic action for every state. In deep RL, is it done using a neural network.
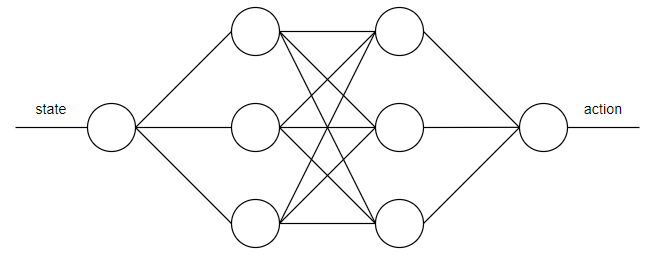
The state and action can be 1-dimensional or k-dimensional.
2. Stochastic Policy
The two most common types of stochastic policies are:
- Categorical Policy: for discrete action spaces
- Diagonal Gaussian Policy: for continuous action spaces
There are two crucial computations needed to use and train stochastic policies:
- sampling actions from the policy
- computing the log-likelihood of particular actions
References
Backlinks
Notes that reference this page.
Connections
Direct relationships to this note.