Teaching Assistant
Arizona State University- Teaching assistant for EEE 480 – Feedback Systems in Fall 2026
- Teaching assistant for EEE 304 – Signals and Systems II in Spring 2025
- Grader for EEE 511 – Artificial Neural Computation in Fall 2025
I am a PhD student in the School of Electrical, Computer and Energy Engineering at Arizona State University, where I work under the supervision of Prof. Jennie Si.
My research focuses on bridging the gap between classical control and reinforcement learning, with broader interests in control, reinforcement learning, real-time embedded systems, and optimization. I am particularly interested in applying these methods to challenging problems in aerospace and motorsports.
Prior to joining ASU, I spent a year as a placement student with the Oracle Red Bull Racing Formula 1 Team, working in the Energy Recovery System Control group. At ASU, I was also part of the Data Acquisition team for Sun Devil Motorsports, ASU's Formula SAE team. Alongside my research, I am currently a teaching assistant for EEE 480 – Feedback Systems and have previously served as a teaching assistant for EEE 304 – Signals and Systems II and as a grader for EEE 511 – Artificial Neural Computation.
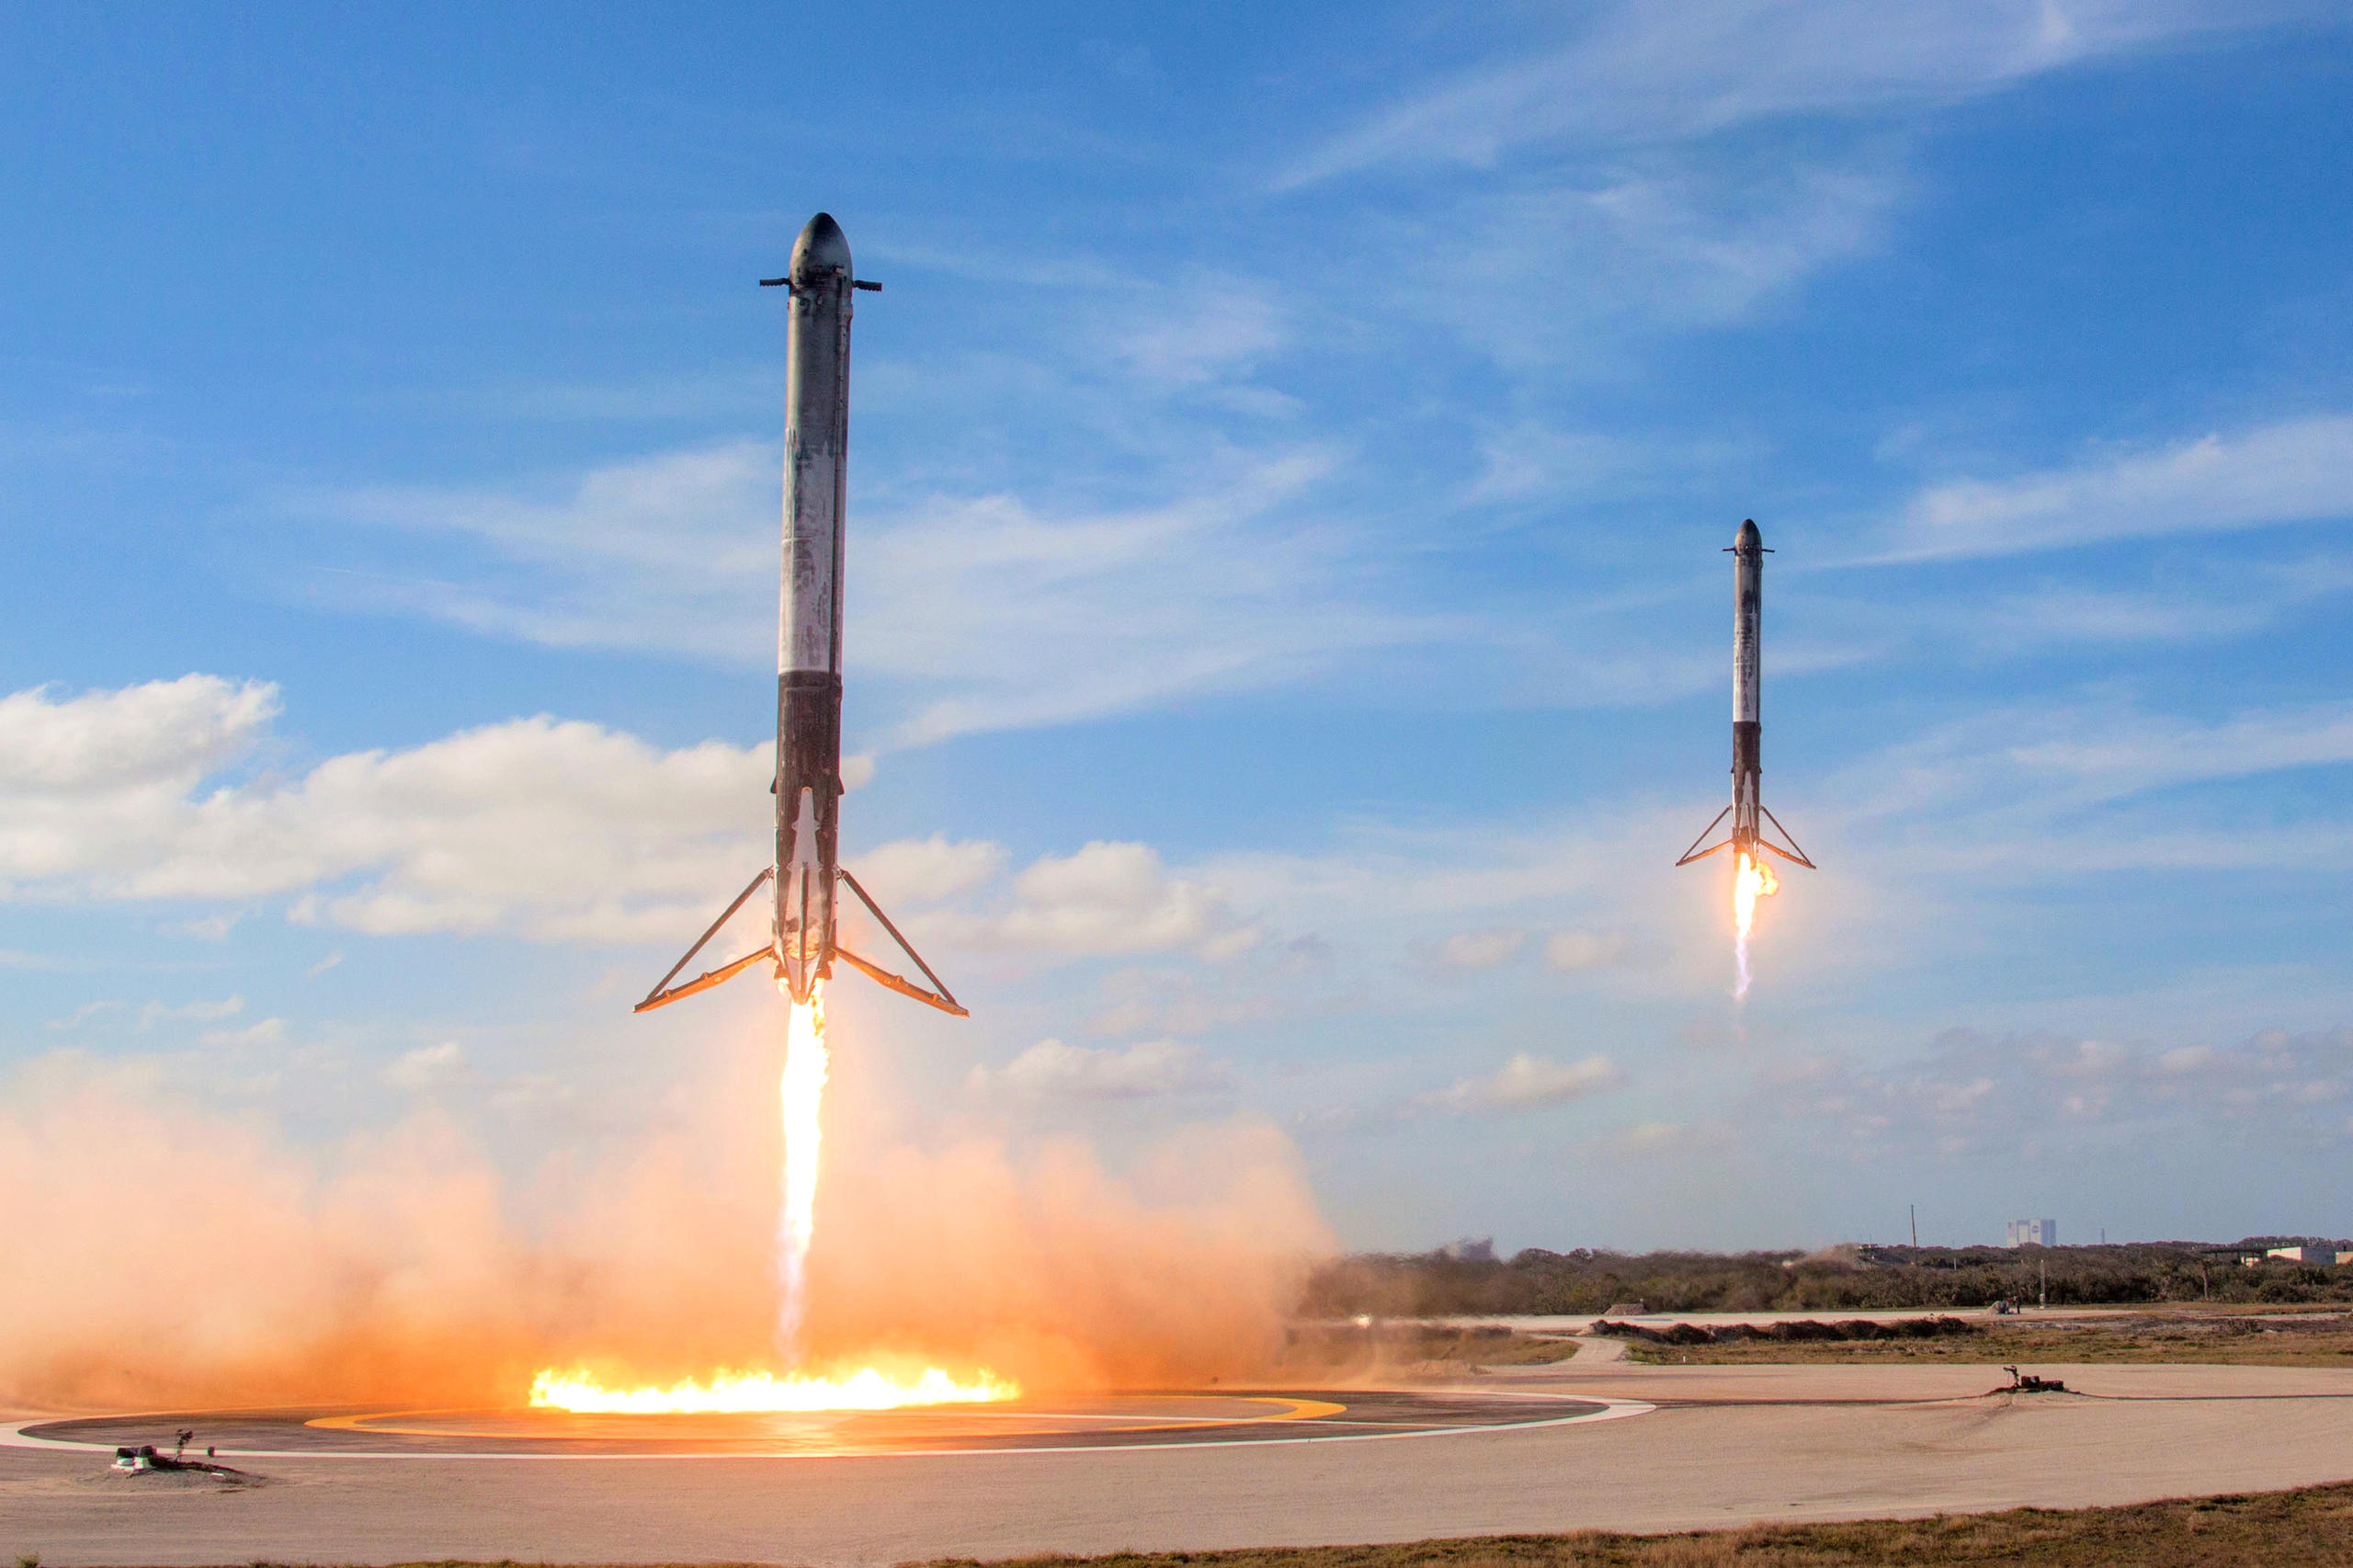
Developed a hierarchical guidance framework for the fuel-optimal landing of a reusable rocket. A nonlinear trajectory optimization problem was solved using successive convexification to generate a fuel-optimal reference trajectory, which was then tracked in real time using Model Predictive Control. The framework was implemented in Python with CVXPY and validated in simulation.
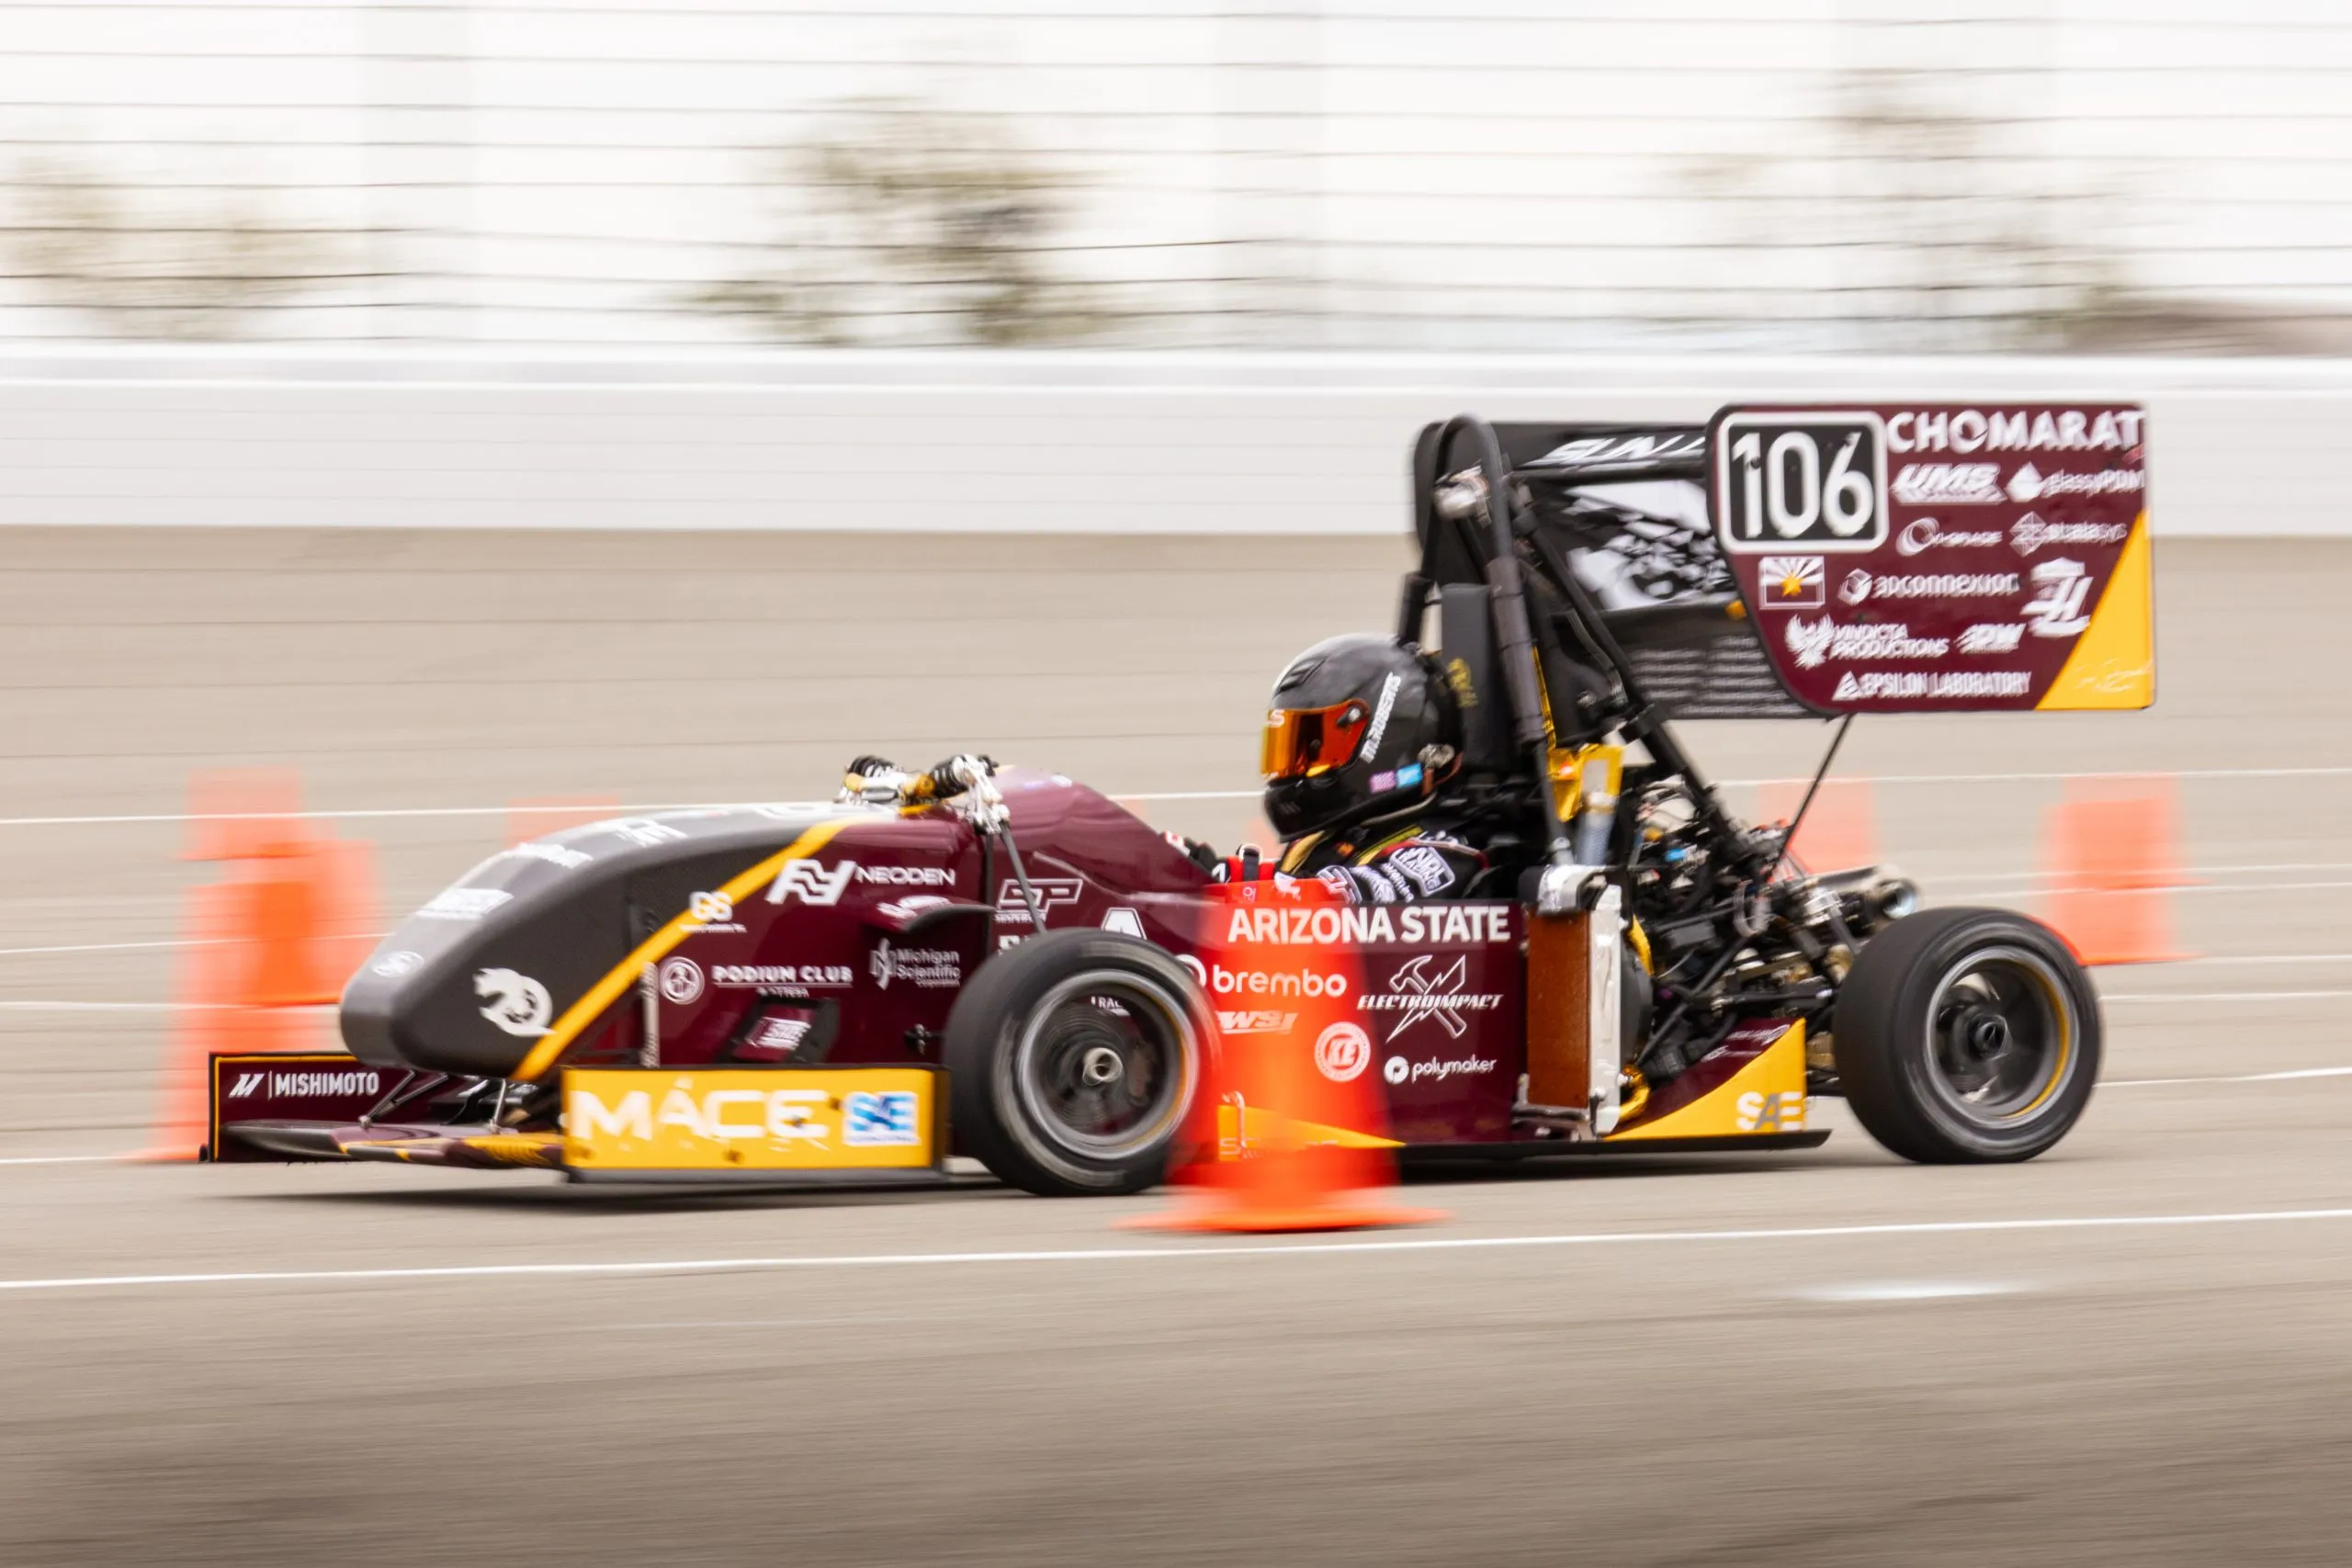
Developed a GPS-aided Inertial Navigation System for vehicle state estimation, designed as a foundation for the ASU Formula SAE car. The system fuses high-rate IMU measurements with lower-rate GPS data asynchronously, using a bank of Linear and Extended Kalman Filters to estimate vehicle position, velocity, acceleration, heading, and gyroscope bias.
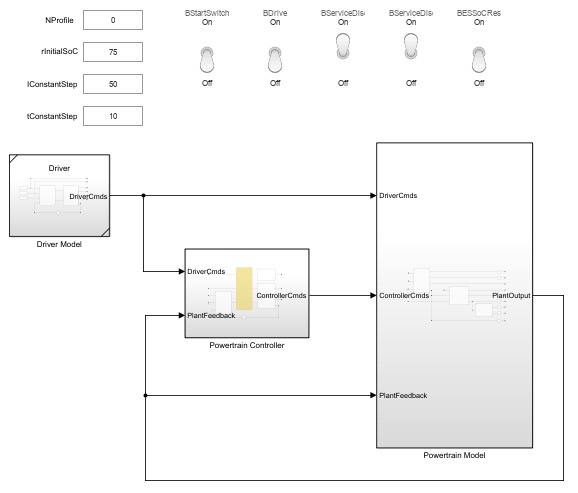
Modeled an electric vehicle powertrain and developed its Electronic Control Unit (ECU) software in Simulink. The control architecture integrates vehicle state control, battery management, and Field-Oriented Control of the electric motor.
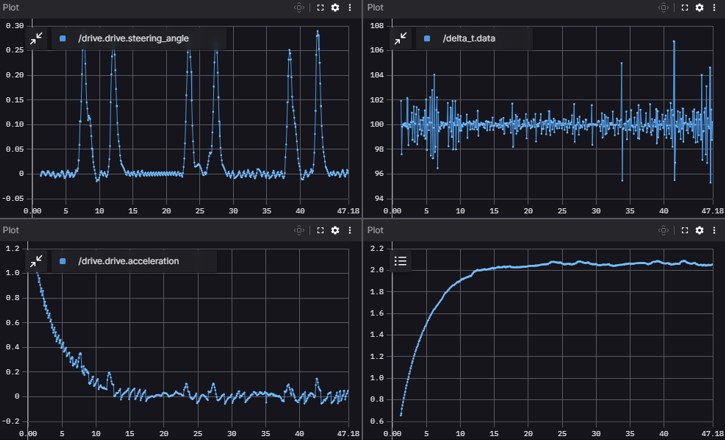
Developed a Model Predictive Controller for autonomous racing with an F1TENTH RC car. The controller follows a reference racing line to navigate the track, with the control algorithm implemented as a ROS 2 node and tested in the F1TENTH Gym simulation environment. The project also integrates a Docker-based ROS 2 simulation stack and data logging using Foxglove.
Arizona State University
Arizona State University
Lebanese American University